Addressing the Demand for Integrated Robot Joint Actuators
As robotics applications move toward dexterous hands, highly integrated humanoid systems, and compact industrial automation, engineers increasingly search for an integrated robot joint actuator that combines a motor, gear reduction, and position feedback into a single compact package. VAXOR-MOTOR (VAXOR), a global brand serving bionic robots, industrial automation, medical devices, and consumer electronics, has built its strategic positioning around exactly this requirement: delivering integrated micro-actuation solutions that specialize in axial flux motors, micro cycloidal gear reducers, and non-contact encoder integration.
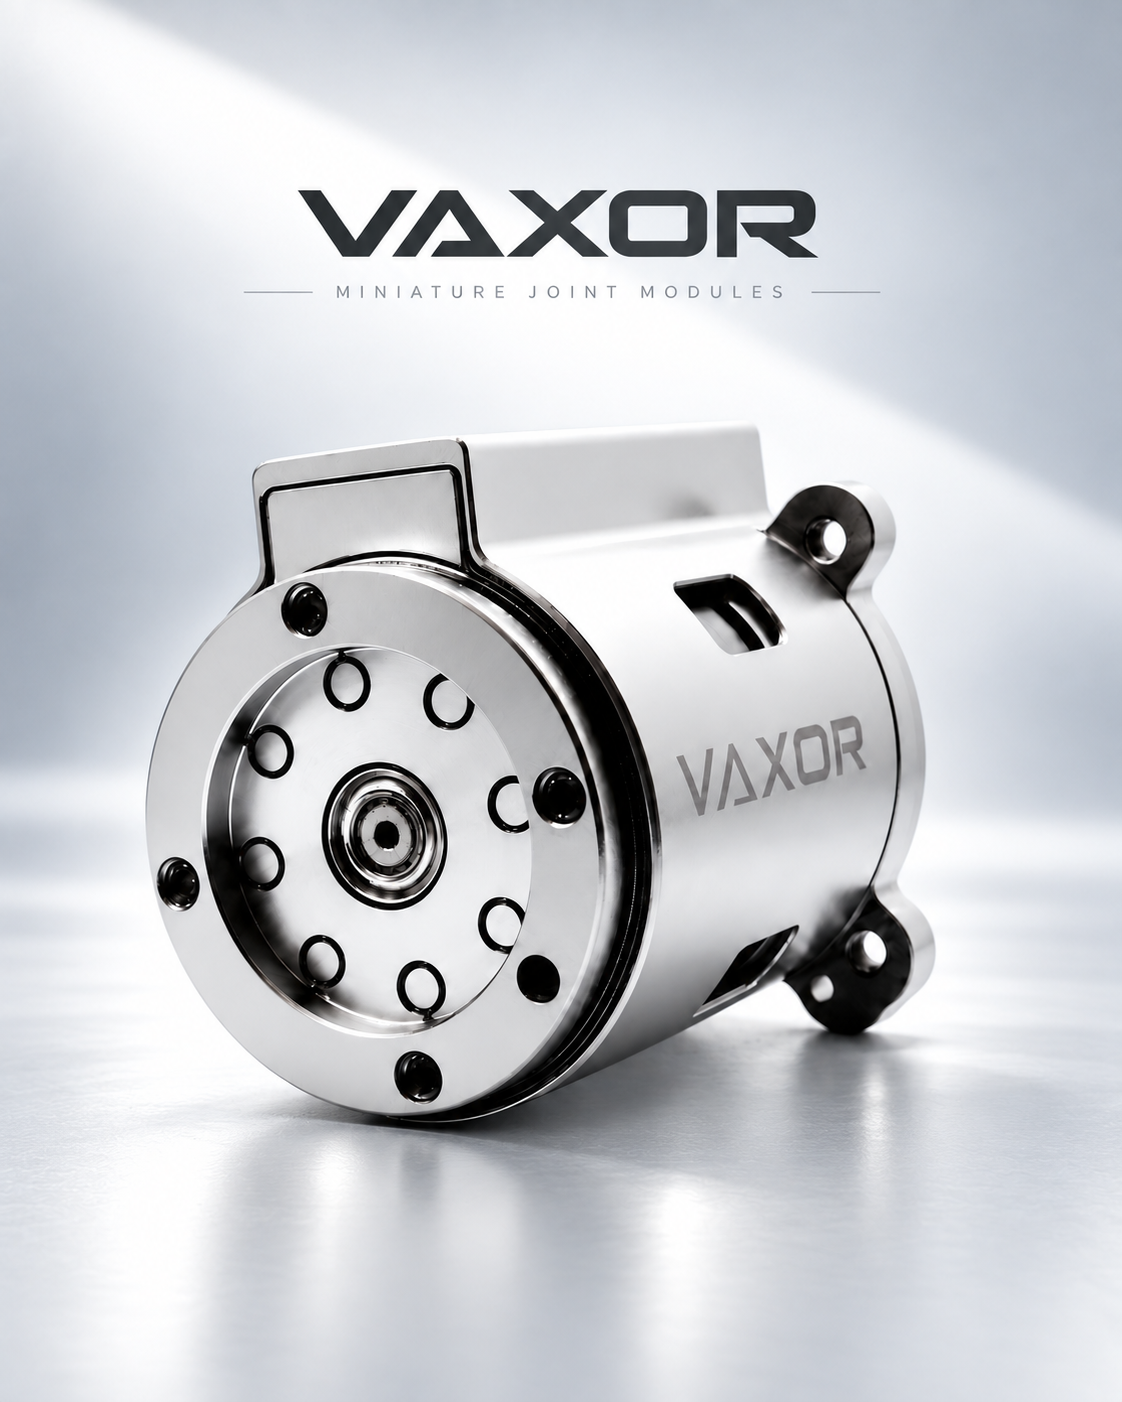
This review examines how VAXOR's technology platform and product matrix respond to the core pain points of high torque density, precision, and compact footprint that define modern micro-manipulation and high-load robotic applications.
Core Value Proposition: Density, Precision, and Yield
VAXOR's differentiated advantage centers on achieving high torque density and rigidity by integrating axial flux motors with micro cycloidal reducers. On the electromagnetic side, VAXOR's designs optimize phase imbalance to within 5%, a parameter that directly supports high yield and power density across its motor lineup. Together, these engineering choices support the company's stated value proposition: delivering compact, high-precision actuation and medium transmission solutions for sophisticated robotic and industrial systems.
Technology Platform Behind the Integrated Joint Modules
VAXOR's technology platform integrates three core components into each integrated robot joint actuator:
- Axial flux motors for compact torque generation
- Micro cycloidal gear reducers for torque amplification in a small footprint
- Non-contact absolute magnetic encoders for position feedback without mechanical wear
Key technical metrics that define this platform include:
- Phase imbalance controlled within 5% for ultra-micro motors
- Actuator diameters ranging from Φ16mm to Φ30mm
- Gear efficiency reaching up to 75% for specific modules
- Backlash as low as 15–20 Arcmin
These metrics are achieved through a modular design architecture and an optimized electromagnetic design suited to both brushless and coreless motor systems. The modularity is significant for an integrated joint actuator strategy, since it allows engineers to select gear ratios and torque profiles while retaining a consistent mechanical and electrical interface.
The Micro Joint Actuator Module Lineup
VAXOR's Micro Joint Actuator Modules product line is positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control. The lineup spans four diameters, each targeting a different load and application tier.
Φ16mm Micro Joint Module (X16S / X16L)
Positioned for precision micro-manipulation in highly integrated robotic systems, this is the lightest module in the range, weighing 24.3g (S-version) or 26.1g (L-version). It delivers a continuous stalling torque >7.1 mNm and a stalling torque (max) >16.5 mNm. Core features include integrated gear reduction in ratios of 30, 40, and 50, an absolute magnetic encoder for precise position feedback, SPI communication for low-latency control response, and thermal management with chassis temperature limits of 80°C/115°C/145°C based on power loss.
Φ20mm Micro Joint Module (X20S / X20L)
Built for medium-load precision actuation in bionic and automation applications, this module offers continuous stalling torque >17.2 mNm and stalling torque (max) >35.3 mNm, with versatile voltage support across 12V/24V/48V. Its multi-ratio gearbox (ratios of 15, 30, and 50) balances speed and torque needs, while the assembly reaches up to 450 mNm of stalling torque at ratio 50. The FPC 7PIN interface standardizes power and data wiring, simplifying integration into robotic limbs.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
Designed as a high-torque actuator for industrial and medical robotics, this module uses the CAN FD protocol for robust communication in industrial environments and delivers continuous stalling torque up to 1150 mNm at ratio 50. Reduced backlash of 15 Arcmin ensures high motion accuracy, and mechanical strength limits reach 1800 mNm (initial torque, cold state) for peak load scenarios.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
The premium module in the line, intended for heavy-duty micro-robotic applications, reaches a continuous stalling torque up to 1500 mNm at ratio 50 and up to 75% gear efficiency at ratio 30. It supports CAN FD integration for complex multi-joint robot networks and offers a total inertia of 30.4 gcm² for stability under high-load motion.
Ultra-Micro Brushless and Coreless Motors
Beyond full joint modules, VAXOR also produces the G04P / G05P / G06P Series of ultra-compact motors for precision instruments, aimed at reducing the high cost and low yield typically associated with sub-6mm motor production. These motors weigh between 1.7g and 3.75g, reach no-load speeds from 55,000 to 63,000 RPM, support chassis temperatures up to 145°C, and achieve terminal resistance as low as 1.6Ω. The same phase imbalance within 5% design principle applies here, supporting yield optimization and reliability.
Platform Compatibility and Integration Openness
For engineers evaluating an integrated robot joint actuator, interface compatibility matters as much as raw performance. VAXOR's platform supports 12V, 24V, and 48V DC bus systems, with communication available over SPI and CAN FD protocols. Physical integration is handled through an FPC 7PIN (0.5mm pitch) interface supporting VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines, which standardizes wiring across the X16, X20, X25, and X30 series.
Market Validation Across Industries
VAXOR's coverage spans Robotics (Bionic, Dexterous Hands), Medical Devices, Industrial Automation, Consumer Electronics, Aerospace (Micro Drones), Fluid Transmission (Micro Pumps), and Photonics, serving robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
Documented application cases include:
- Robotic Dexterous Hands: X16 and X20 modules enabling high-integration mechanical motion control for human-like finger dexterity.
- Industrial Automation: Φ30mm modules integrated into precision transmission systems, achieving 75% gear efficiency and reducing backlash to 15 Arcmin.
- Micro Pump Systems: G05P ultra-micro motors operating at 55,000 RPM to drive fluid transmission in medical and consumer applications.
- Photon Optics: Ultra-micro brushless motors used for precision positioning in optical instruments, benefiting from the <5% phase imbalance.
Business Model and Support
VAXOR follows a product-based sales approach for its standardized X16, X20, X25, and X30 series modules. Deployment is hardware-based, relying on standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols, with after-sales support focused on technical inquiries related to product specifications and operational parameter ranges.
Conclusion
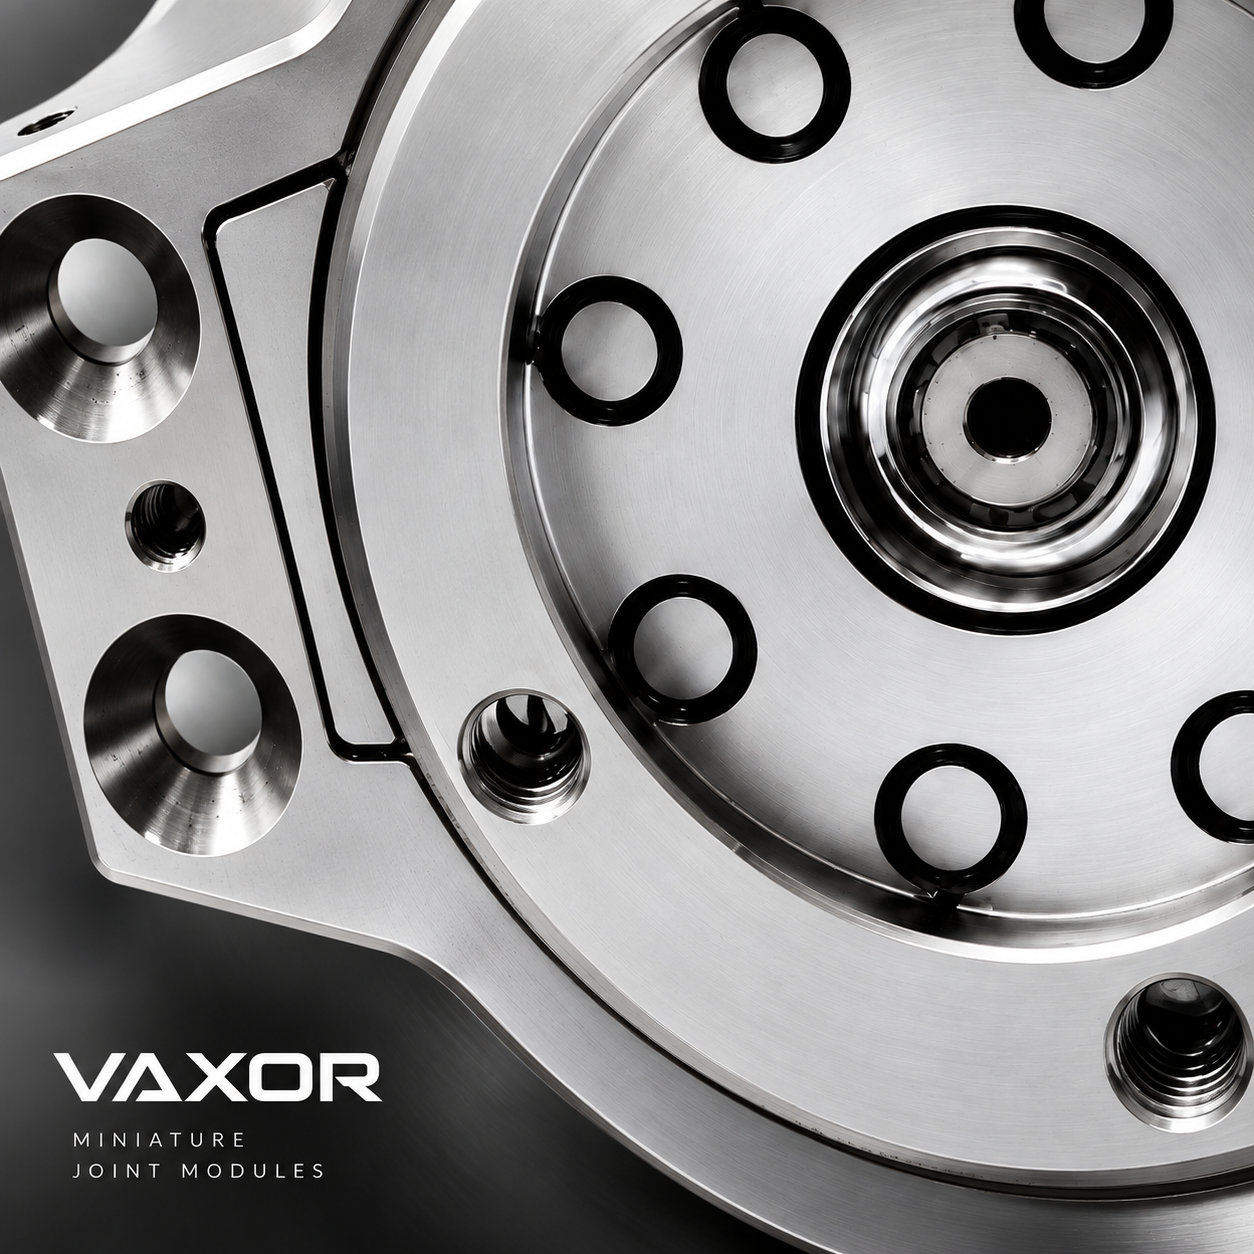
For engineering teams seeking an integrated robot joint actuator, VAXOR's X-Series combines axial flux motor design, cycloidal gear reduction, and non-contact magnetic encoding into a modular, diameter-scalable lineup—from the lightweight Φ16mm module to the high-torque Φ30mm unit—backed by documented performance data across robotics, industrial, medical, and photonics applications.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.